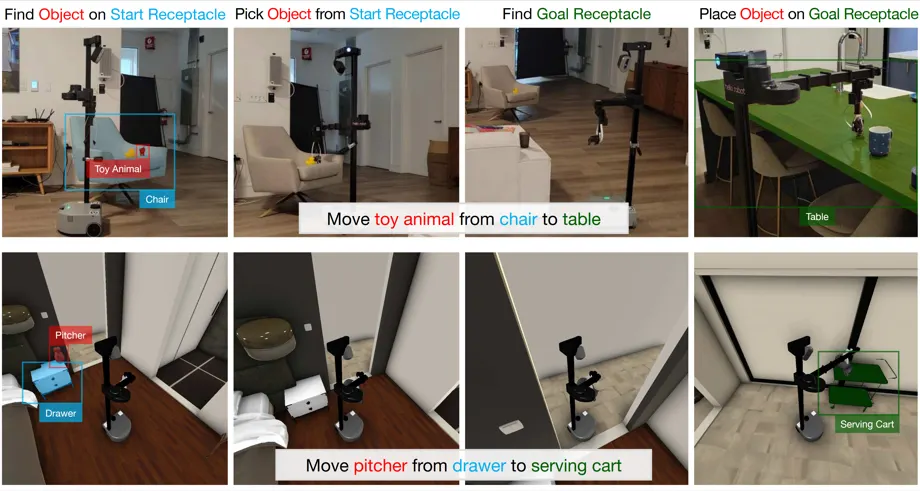
HomeRobot
How do you measure whether a robot can fetch an unfamiliar object? We built a benchmark that labs can run in simulated homes and on a real Stretch robot.
Robotics researcher
I work on getting robots to do useful things in places they haven’t seen before. I study how robots learn to move, grasp, and follow instructions, and I build open-source tools to see how well those skills hold up in real homes.
Read my résumé
How do you measure whether a robot can fetch an unfamiliar object? We built a benchmark that labs can run in simulated homes and on a real Stretch robot.
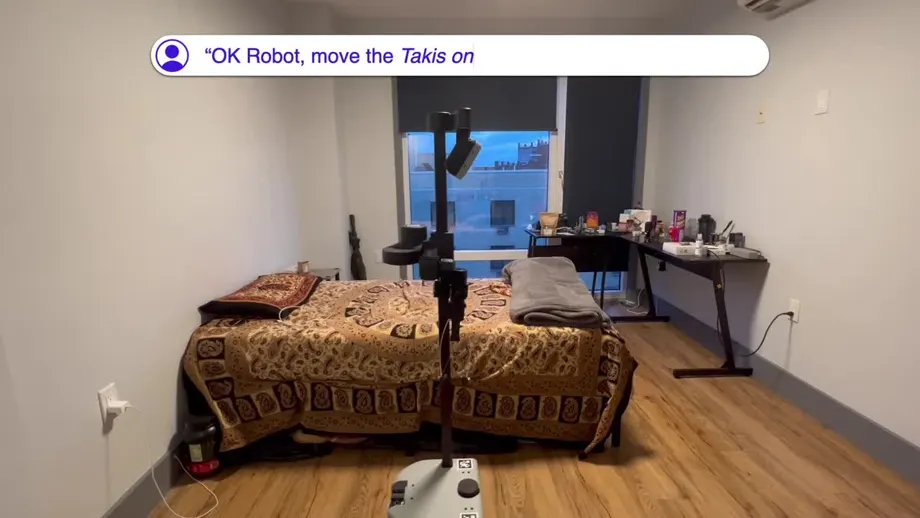
We brought a mobile manipulator into ten real homes. Using pretrained models, it completed 58.5% of pick-and-drop tasks without training in those homes.
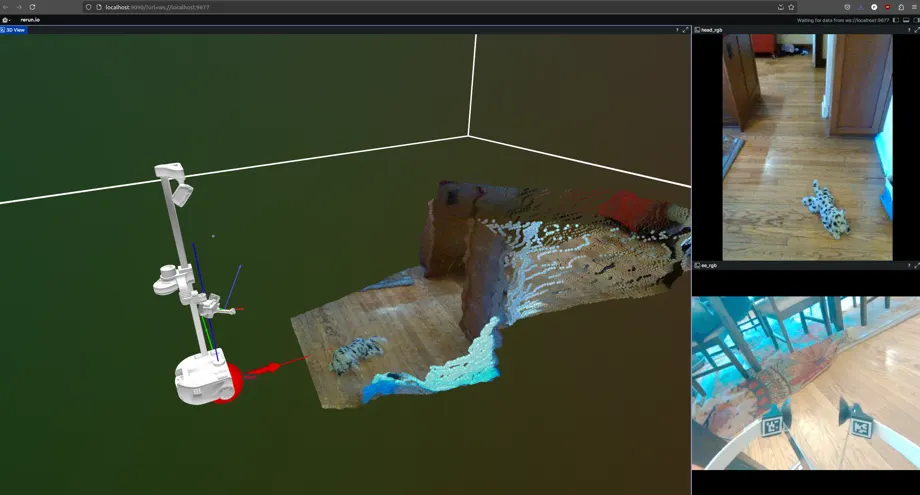
An open-source toolkit for building on a Stretch. Give the robot a spoken instruction, let it explore a room, or teach it a new skill by demonstration.
I work through what it would take to collect two trillion tokens of robot experience using fleets, simulation, and human video.
Predicting how a scene will change is one thing. How does a robot turn that prediction into its next action?
If robot labor became cheap, what work would we take on that nobody can justify doing today?
I co-host RoboPapers, where we interview researchers about the experiments behind their papers.
Daniel Ho joins Michael Cho and me to discuss how 1X uses a world model to evaluate a robot and choose its next action.
Jianyuan Wang explains how a single feed-forward model recovers camera positions and 3D scene geometry from images.
Han Zhang and Mengda Xu walk us through how they collect demonstrations with a human hand and transfer those skills to a robot hand.